UCLA Samueli
UCLA Samueli
Q&A with Professor Jiaqi Ma
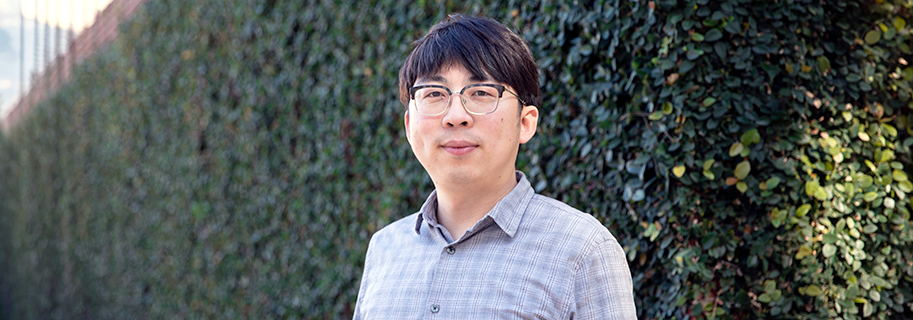
Jiaqi Ma is director of UCLA’s Center of Excellence on New Mobility and Automated Vehicles funded by the Federal Highway Administration. He is also a professor of civil and environmental engineering and computer science at the UCLA Samueli School of Engineering, where he researches the future of transportation and mobility. He earned his B.S. and M.S. in civil engineering from Beijing Jiaotong University and his M.S. and Ph.D. in civil and systems engineering from the University of Virginia. His work explores how artificial intelligence, connected vehicles and automated driving technologies can make transportation safer, more efficient and more sustainable. He leads research on emerging mobility technologies and their potential to transform how people and communities move.
“Transportation is not only an application of AI; it is an important proving ground for developing AI that is dependable enough to improve daily life.”
Q: What are some of the main research projects that you are focusing on this academic year?
A: This year, my research group at the Mobility Lab is concentrating on three connected directions. The first is cooperative perception and intelligent infrastructure: enabling vehicles and intersections to share what they can see so they can detect risks that no single camera or vehicle could observe alone, such as a pedestrian hidden behind a truck. The difficult questions are not only technical accuracy, but also trust, timing, reliability, interoperability, and how these systems perform outside the laboratory. We are therefore moving from simulation to smart intersections, closed-track testing, and real-world pilots in partnerships with many original equipment manufacturers, automated driving system developers, and infrastructure owners and operators.
The second direction is developing a cognitive core for autonomous vehicles and robots. We are using multimodal foundation models, including vision-language-action models, to help machines understand a scene, reason about what may happen next, and act quickly, reliably, and responsibly. The third is mobility digital twins and world models: high-fidelity virtual representations that allow us and our public-agency partners to test how a technology or policy could affect an entire transportation system before making costly changes in the real world. Together, these projects advance physical AI from individual algorithms toward safe, deployable systems.
Q: How do you work with undergraduate and graduate students on these research projects? What are your key priorities and goals when advising students?
A: Students are embedded in multidisciplinary project teams and given meaningful ownership. Undergraduate students may begin with a well-defined component, dataset, or experiment, while graduate students take greater responsibility for framing research questions, developing new methods, integrating systems, and leading demonstrations. Across all levels, I want students to see how their work connects to a larger goal and to the people who may ultimately use the technology.
My priority is to teach the complete process of solving an important problem: understand the real need, translate it into a rigorous research question, develop the necessary components, integrate them into a working system, evaluate the system honestly, and communicate the results clearly. Publishing strong scholarship is essential, but it is only one part of that process. Students also learn to collaborate across disciplines, work with public agencies and industry partners, mentor others, and take responsibility for the quality of the final result. My goal is for them to leave UCLA as independent researchers, capable engineers, and emerging leaders who can carry an idea from first principles to real-world impact.
Q: How will your research be translated into new technologies?
A: Translation is built into the way we organize our research. We often begin with a need identified by a transportation agency, an industry partner, or a community, and then work backward from real deployment constraints. Instead of stopping with an individual research paper, we build integrated software, datasets, simulation and digital-twin environments, vehicle and roadside prototypes, and field demonstrations. For example, our cooperative-perception work is tested through smart intersections and closed-track experiments, while our digital twins help agencies evaluate system changes before investing in physical deployment.
We also make many research tools and datasets available to a broader community so that other universities, agencies, and companies can reproduce and extend the work. By involving end users early, testing under realistic conditions, and improving the system through repeated feedback, we can turn scientific advances into reusable methods, standards, and eventually deployable products. A paper can explain why a method works; translation requires showing how many methods work together as a dependable system.
Q: How could private funding through donor gifts enable you to further your research at UCLA?
A: Private support provides something especially valuable in a fast-moving field: the flexibility to explore a promising idea before it fits neatly within a traditional sponsored project. Government research grants are extremely important, but they are usually tied to a defined scope, schedule, and set of deliverables. Donor funding can help us respond quickly to an emerging opportunity, test a high-risk idea, connect expertise across disciplines, and produce the early evidence needed to attract larger public or industry investment.
It can also directly support students, real-world data collection, sensors, field demonstrations, and shared research infrastructure. Modern AI research is highly compute-intensive, and access to advanced computing often determines how rapidly we can train, evaluate, and improve a system. Flexible gifts can expand our computing capacity, sustain open-source tools and testbeds, and give students the resources to turn an early concept into a convincing prototype. In this way, donor support does more than fund an isolated experiment; it creates room for discovery and helps bridge the difficult gap between a new idea and a technology that can benefit society.
Q: What are some of the biggest challenges in applying artificial intelligence to real-world transportation systems, and what opportunities do you see for this technology to improve everyday life?
A: Transportation is both open-world and safety-critical. An AI system must handle rare events, construction, weather, occlusion, unpredictable human behavior, changing road conditions, and failures in sensors or communications. It must make useful decisions in real time while recognizing when it is uncertain. Data quality varies across locations and communities, existing transportation infrastructure was not designed around AI, and public agencies need systems whose behavior can be tested, explained, monitored, and trusted.
For these reasons, the most effective approach is not simply to replace one conventional component with an AI model. We need AI-native systems that combine perception, prediction, reasoning, safety monitoring, and human oversight from the beginning. If we do this responsibly, the opportunities are enormous: fewer crashes, more independent mobility for older adults and people with disabilities, more reliable transit, faster incident response, less congestion and emissions, and more efficient movement of goods. Connected vehicles and intelligent infrastructure could also protect people beyond the line of sight of any one driver or sensor. Transportation is therefore not only an application of AI; it is an important proving ground for developing AI that is dependable enough to improve daily life.
Q: What developments in artificial intelligence and transportation are you most excited to see, and why?
A: I am most excited by the shift from narrowly specialized AI models to embodied, or physical, AI that can understand complex scenes, interpret goals and instructions, reason about consequences, and take action in the physical world. Multimodal foundation models and vision-language-action models are important parts of this shift because they can connect perception, knowledge, and behavior in ways that were previously difficult to achieve.
The real breakthrough, however, will be making this intelligence safe, verifiable, and cooperative. I expect future systems to combine fast safety mechanisms with higher-level reasoning, rather than relying on a single large model for every decision. Vehicles, robots, and infrastructure will increasingly share information and learn from high-quality digital twins and world models. This could transform transportation from a collection of isolated machines into a coordinated mobility ecosystem in which systems anticipate risks, assist one another, and adapt to changing needs. The field is moving quickly, and UCLA has an opportunity to help define not only what these technologies can do, but also how they should be evaluated and deployed responsibly.